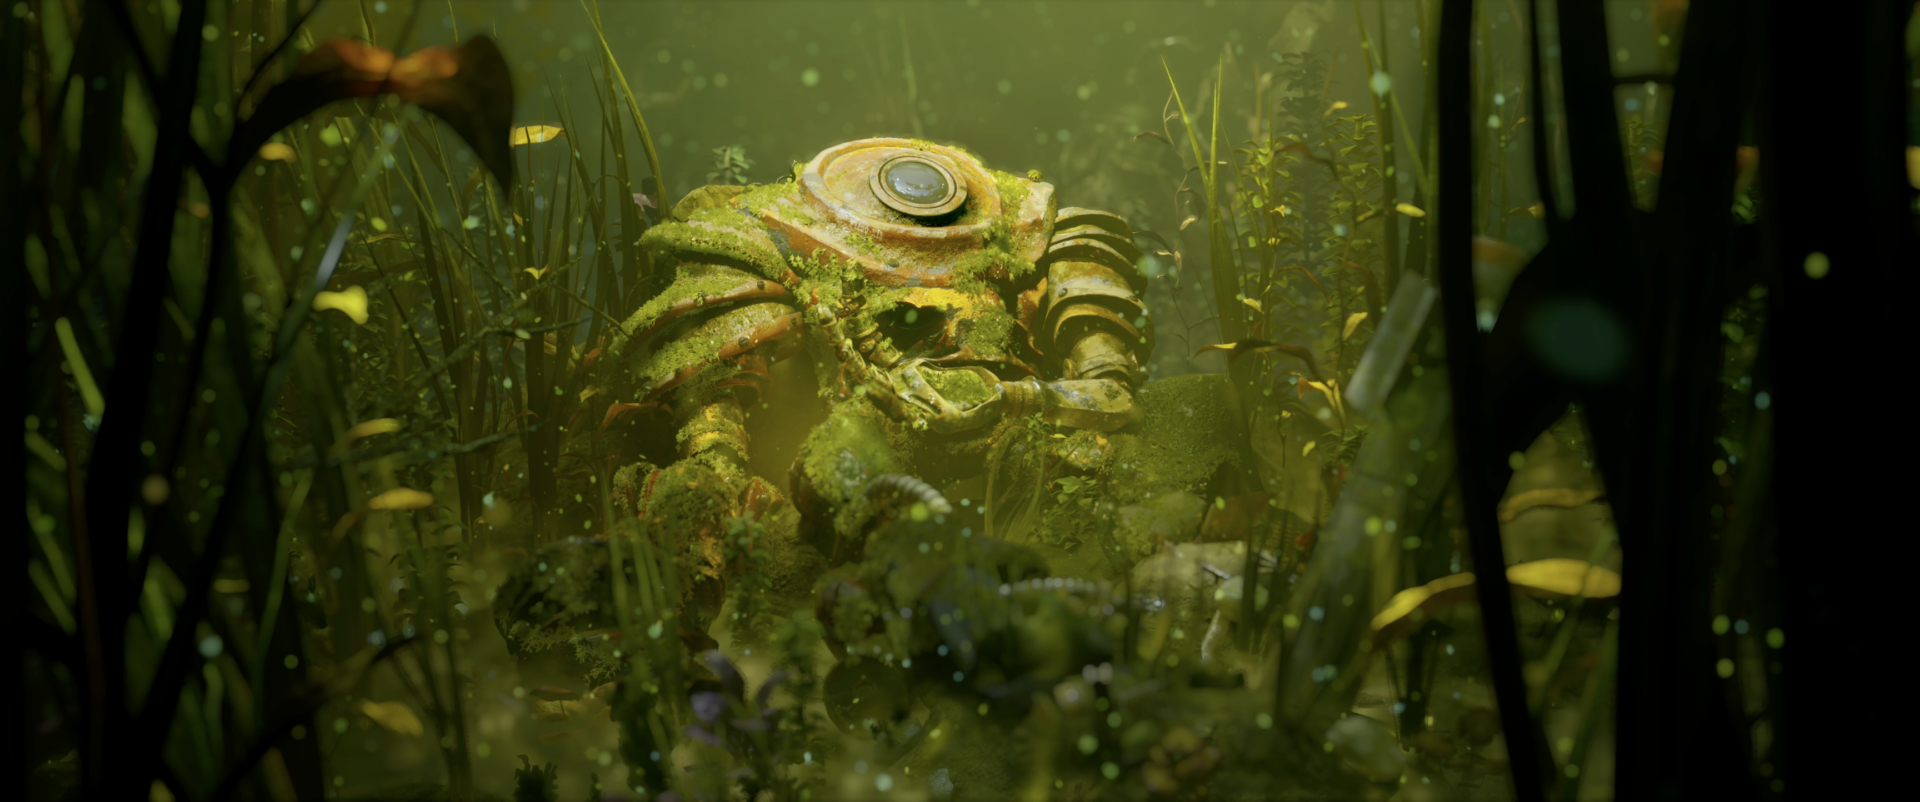
Fall 2023. Senior Vertical Studio at Texas A&M University Visualization
Lakewarden is my senior animated short film for Texas A&M Visualization Vertical Studio, created with a team of eight others over the course of one semester. In addition to my lead and auxiliary roles, I also took on project management responsibilities alongside two other co-project managers. Though I had limited experience with Unreal Engine prior to the project, I became thoroughly proficient in UE throughout development. Guiding a large team to ensure Lakewarden’s success was a task that demanded significant time, organization, research, and no shortage of drive.
As Lighting Lead, I developed a global lighting setup along with two shot-specific setups. I created the realistic murky underwater look and utilized value / contrast to direct viewers towards the robot and minnow. I was also responsible for the algae VFX on the robot, rigging the robot’s arm, assistance with rendering, some layout concept art, and tertiary lookdev/surfacing.
Roles: Project Management Lead, Lighting Lead, Pipeline Lead, VFX, rigging, rendering, concept art, tertiary asset surfacing.
Software Used: Unreal Engine 5, Autodesk Maya, Houdini, Adobe Substance Painter, Adobe Premiere
Showcases: Brazosport Arts in Media Festival (2024), Viz-a-Gogo (2024), Visualization Fall Show (2023).
Lighting
For the lighting, I developed a global lighting setup along with two shot-specific setups. Extensive visual research was conducted to realistically capture the murky appearance of dirty ponds and lakebeds. I aimed for a realistic underwater look while also artistically drawing the viewer’s attention to the robot and minnow, creating an appealing composition with a wide range of values and contrast.
I received lighting guidance from Myriah Higgins, lighting artist at Bluepoint Games, throughout the project.
Algae VFX
One of my major technical hurdles was to create a procedural algae tool that could scatter algae on the robot’s body and hand. I created a procedural algae tool for the robot’s body and arm using SideFX Houdini.
The tool includes a point scatter system which creates instances of a low-poly plant mesh. Instances are generated only on masked areas of the robot’s body and arm, which are then exported out as one model. The arm would also intake animation data to move the algae consistently along with the arm and finger movements.
Arm Rig
I created the rig for the robot’s arm with a joint + control system setup, including an IK/FK switch on the elbow. (FK version shown.) All systems were created from scratch and optimized to easily achieve proper robotic animation.
My main challenge was to weight paint a mechanical object, as my previous rigging experience was an organic character. On this robot, I focused on making the rig as mechanical and binary as possible via weight painting.